Paying for Space: Incentive-Aware Motion Planning for Multi-Agent Collision Avoidance
IEEE CDC 2026 · Accepted
Multi-Agent Systems
Motion Planning
Optimal Control
Mechanism Design
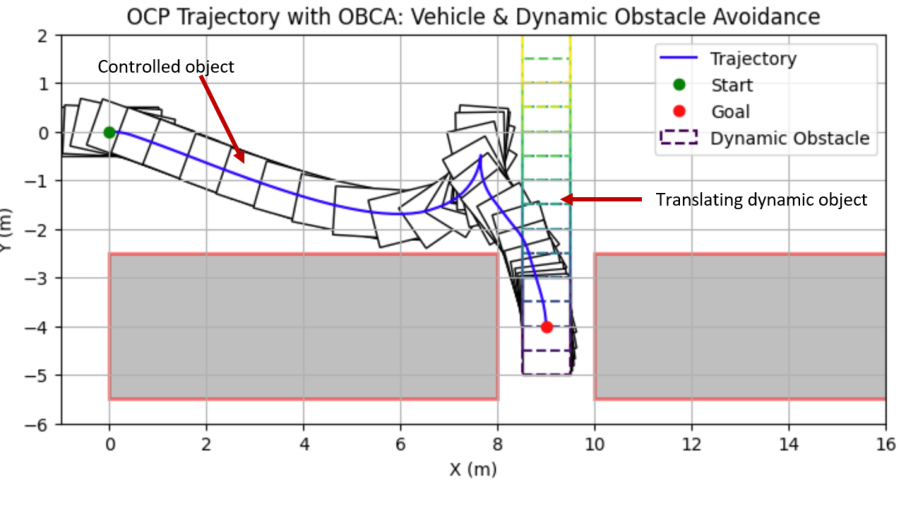
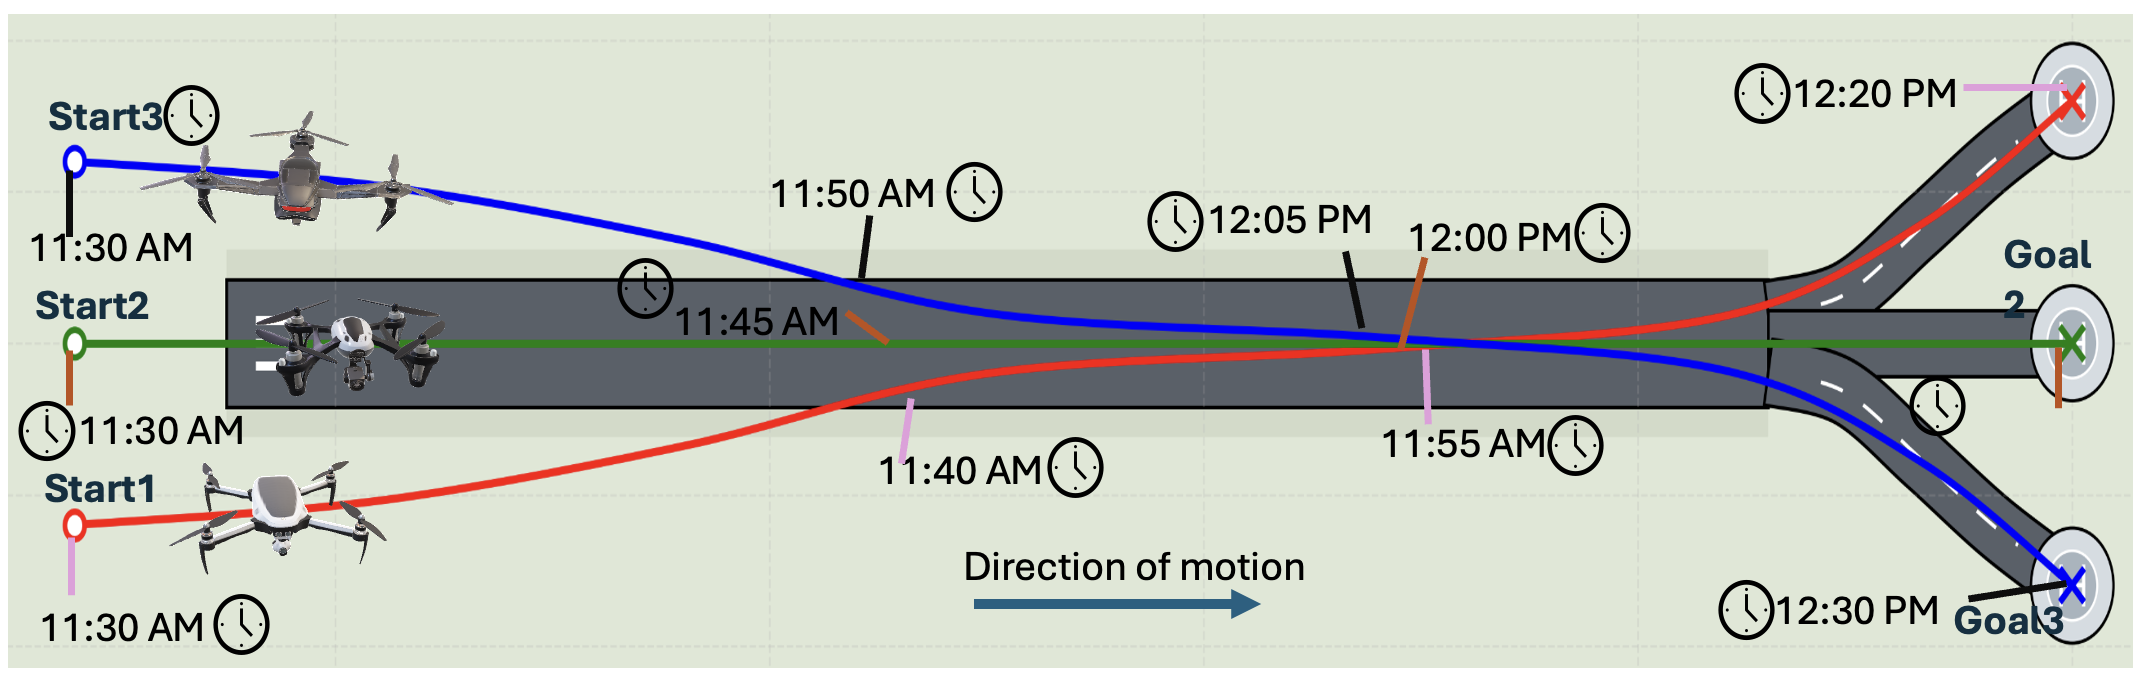
Developed an incentive-aware multi-agent motion planning framework for agents with heterogeneous private preferences.
The method combines bilevel optimization, convex safe-corridor allocation, decentralized trajectory execution, and VCG-inspired transfers to coordinate collision-free motion under strategic agent behavior.